Sub-pixel camera and object tracking standards engineered for seamless downstream VFX integration.
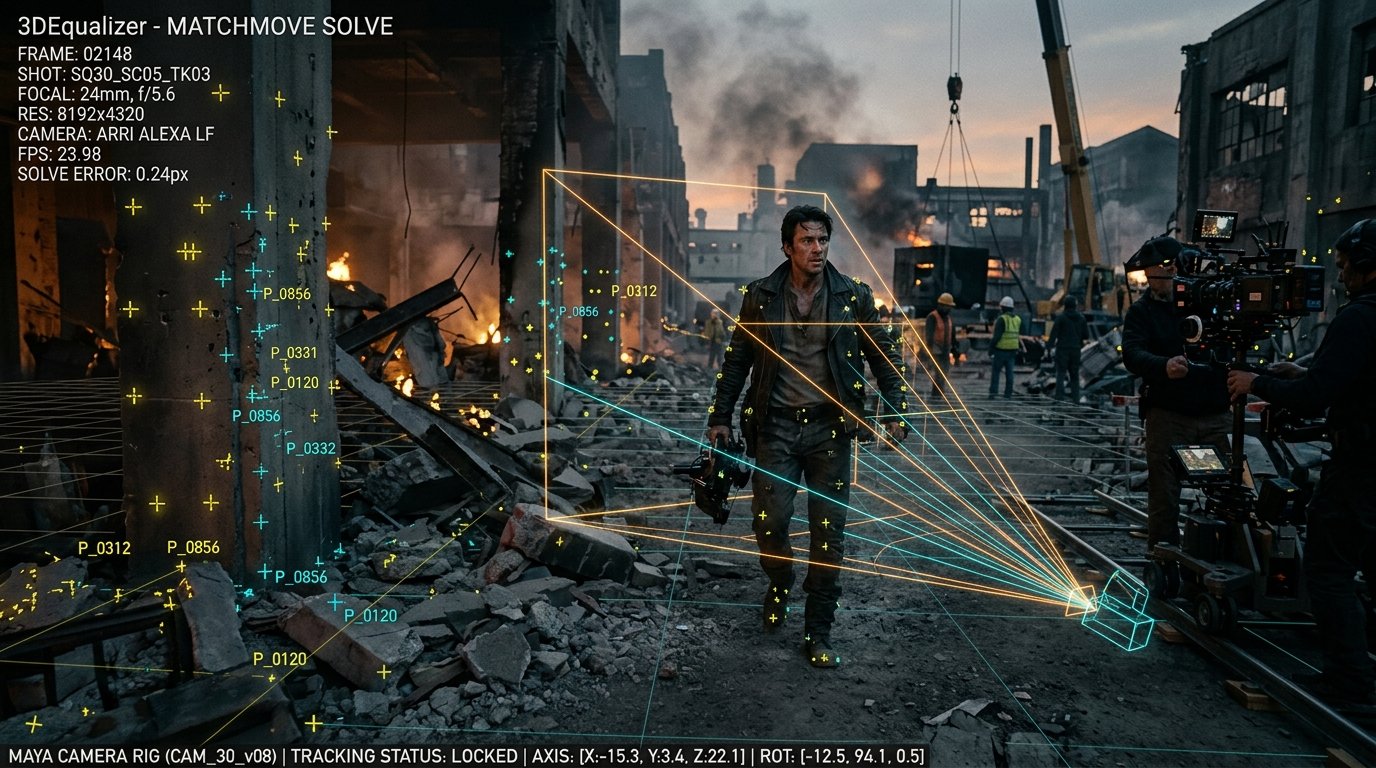
Industry-standard camera solves with deviation under 0.5 pixels across complex handheld, drone, Technocrane, and fast-pan motion plates.
Generating precise un-distortion and re-distortion ST maps matching anamorphic optical breathing, chromatic aberration, and barrel distortion.
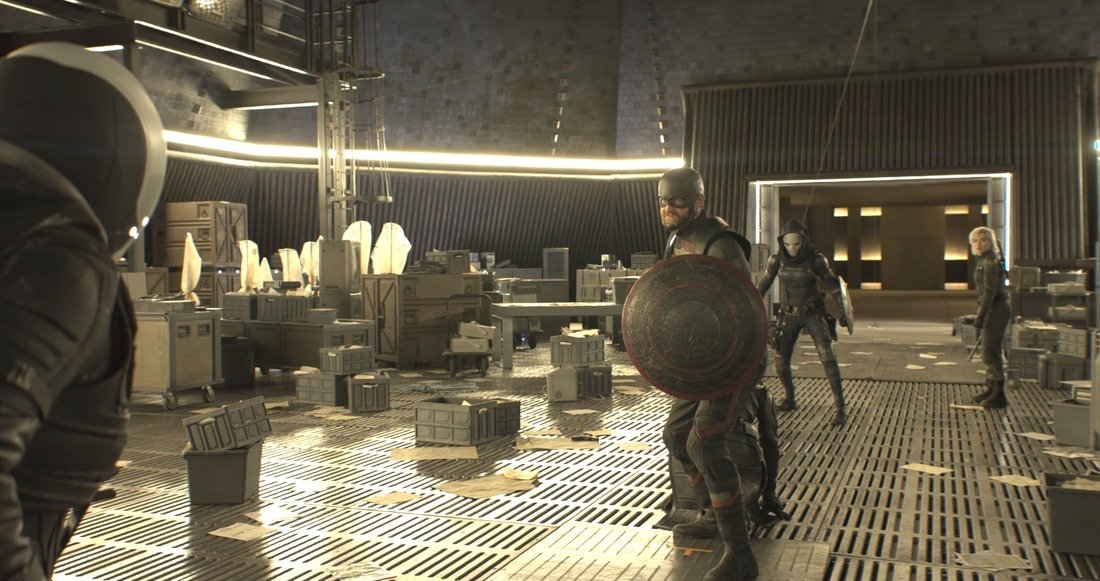
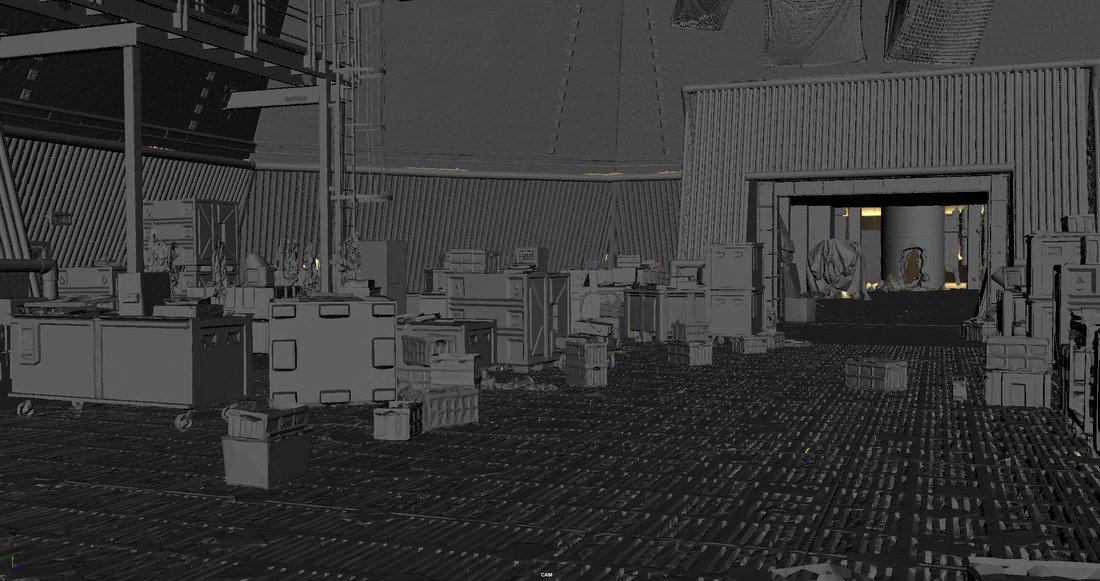
Aligning camera solves to on-set total station survey points and dense 3D LIDAR point clouds for millimeter-accurate set reconstruction.
Dynamic 3D tracking for fast-moving vehicles, weapons, aircraft, and mechanical props with rigid 3D geometry alignment.
Camera and geometry deliverables formatted to plug seamlessly into Maya, Houdini, Blender, and Nuke.
Fully baked camera nodes, focal length animation curves, filmback dimensions, and locator point clouds.
Ogawa Alembic camera and survey geometry cache for cross-platform Maya, Houdini, and Unreal Engine workflows.
ST Map 32-bit EXR distortion maps, 3DE Nuke plugin nodes, and grid calibration charts for comp undistortion.
Native `.3de` session files including complete point weightings, survey alignments, and solve residual logs.
Send us your test shots or sequence turnover specs. Our production coordinators are standing by for immediate bidding and capacity scheduling.